DEAL-Grasp: Decoupled Alignment Representation for Geometry-Aware Dexterous Grasp Generation
Dalian University of Technology
* Corresponding author


Abstract
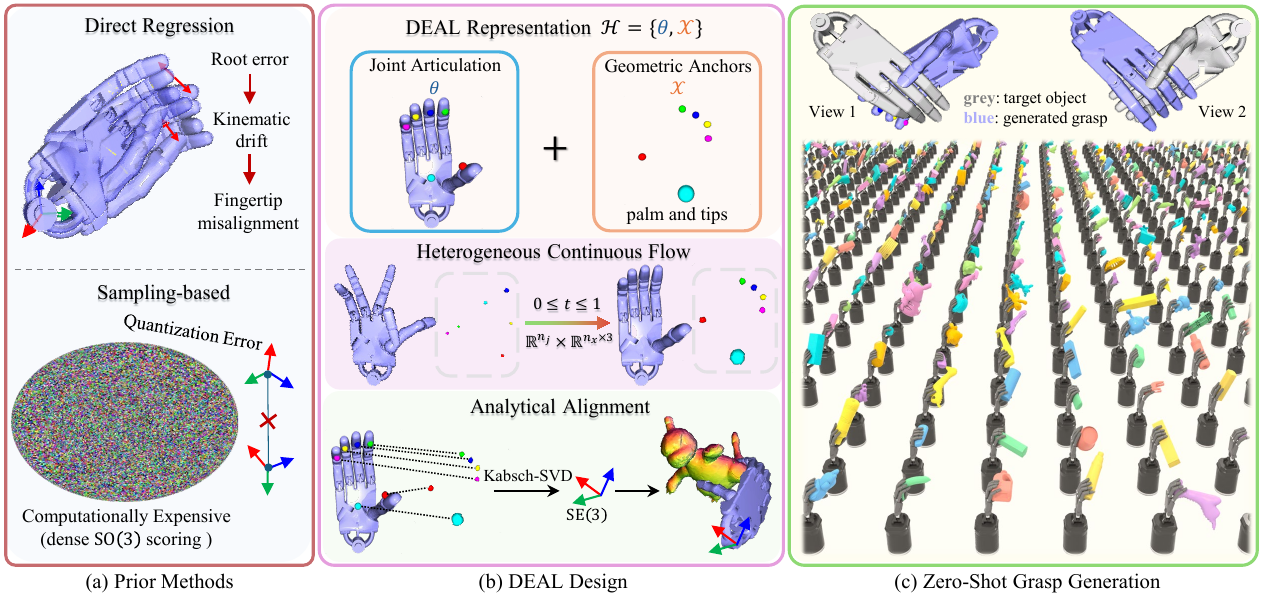
Synthesizing realistic articulated hand–object interactions is a fundamental problem in virtual reality, embodied intelligence, and digital human applications. Existing methods for dexterous grasp synthesis typically regress or denoise poses in a joint space that couples global rigid motion with local articulation, which often yields unstable samples and physically implausible contacts. We introduce DEAL-Grasp, built upon the Decoupled Alignment (DEAL) representation, which reformulates grasp synthesis as alignment-space generation: the interaction state comprises task-space geometric anchors and articulation parameters, from which the rigid transform is recovered via closed-form Procrustes alignment while preserving local articulation. On this mixed state, we model grasp generation using heterogeneous-state flow matching with component-wise vector fields, incorporating time-adaptive physical regularization during training. At inference, grasps are synthesized solely by integrating the learned vector field, without test-time optimization or auxiliary physical guidance. Across MultiDex and zero-shot RealDex benchmarks, DEAL-Grasp attains high force-perturbation success rates alongside minimal penetration and high diversity of generated grasps, while substantially reducing native inference latency compared to optimization-heavy baselines.
Video
This supplementary video presents the core motivation, outlines the DEAL representation design, and demonstrates physical validation on a UR10e manipulator mounted with a Shadow Dexterous Hand.
BibTeX
@misc{zhao2026dealgraspdecoupledalignmentrepresentation,
  title   = {DEAL-Grasp: Decoupled Alignment Representation for Geometry-Aware Dexterous Grasp Generation},
  author  = {Fuqiang Zhao and Qian Liu},
  year    = {2026},
  eprint  = {2609.28131},
  archivePrefix = {arXiv},
  primaryClass = {cs.RO},
  url     = {https://arxiv.org/abs/2609.28131},
}